Embedded Platforms in Robotics: How They Power Robots
Performance per watt matters as much as raw speed. Collaborative robots (cobots). Cobots work alongside people, so the platform must respond quickly to contact and speed changes.
 aaronnelectronicsgmbh
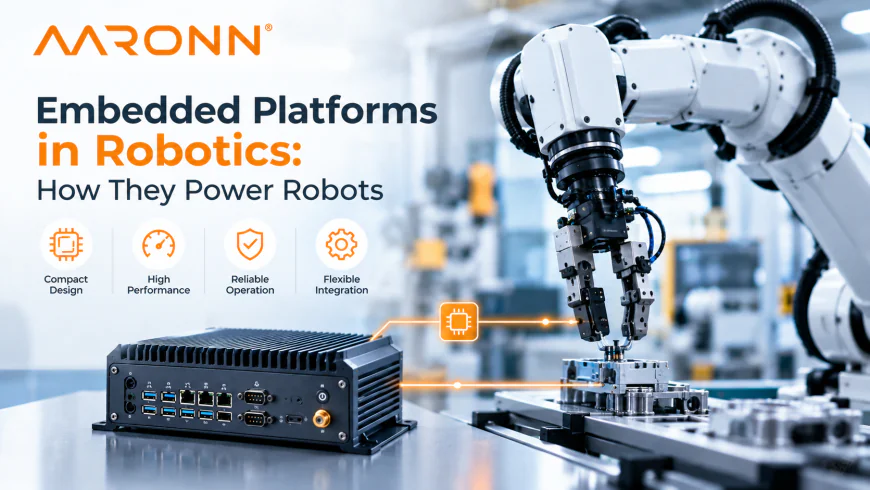
Every robot, from a warehouse AMR to a collaborative arm on an assembly line, has a computer at its core. It reads the sensors, decides what to do next and tells the motors how to move, often many times per second. That computer is the robot's embedded platform.
Choosing it well determines how much the robot can see, how fast it reacts and how long it runs on a battery. This article explains what an embedded platform does inside a robot, which platform types exist and how to match one to your application. In German speaking markets the topic is often searched as embedded plattform robotik, and the engineering principles are the same everywhere.
What Is an Embedded Platform in Robotics?
An embedded platform for robotics is the dedicated computing hardware built into a robot to run its perception, decision making and control software. Unlike a desktop PC, it is designed for a fixed task, a confined space, limited power and an environment with vibration, dust and temperature changes.
The platform can be a bare board inside the robot's chassis, a compact module on a custom carrier board, or a rugged embedded PC mounted in the robot or its control cabinet.
The Four Jobs an Embedded Platform Does
1. Perception
Robots understand their surroundings through cameras, lidar, ultrasonic sensors and encoders. The embedded platform collects this data and turns it into something useful: an obstacle map, a detected part, a person entering the work zone.
2. Decision making and AI
Once the robot knows what is around it, it has to decide what to do. That includes path planning, task scheduling and, increasingly, AI inference for object recognition or grasp detection. Running AI on the robot itself, rather than in the cloud, keeps reaction times short and avoids dependence on a network connection.
3. Motion control
Decisions become movement. The platform sends commands to motor drives and reads feedback in tight, regular cycles. Industrial fieldbuses such as EtherCAT are widely used here. Some vendors now run motion control software directly on the main embedded computer acting as the EtherCAT master, which removes the need for separate motion controller hardware.
4. Communication
Robots rarely work alone. The platform connects to fleet management systems, PLCs, MES software and other robots, usually over Ethernet or Wi Fi, and increasingly over 5G in larger facilities.
Did you know? Many modern robots run ROS 2, the open source Robot Operating System. The choice of embedded platform affects which ROS 2 packages and hardware acceleration features you can use, so check software support before you choose hardware.
Types of Embedded Platforms for Robotics
|
Platform type |
What it is |
Best fit |
|
Single board computer (SBC) |
Complete computer on one board in a standard form factor |
Compact robots, prototypes, simple control tasks |
|
Computer on Module (COM) |
Processor module plugged into a custom carrier board |
Series produced robots needing a tailored design and upgrade path |
|
Edge AI module |
Module with GPU or AI accelerator, such as NVIDIA Jetson |
Vision heavy robots, AMRs, AI based picking |
|
Embedded box PC |
Rugged, enclosed system ready to mount |
Robot controllers, cell computers, retrofits |
|
Industrial motherboard |
Standard board with expansion slots |
Stationary systems needing PCIe cards or many interfaces |
Edge AI in numbers: NVIDIA's Jetson Orin family ranges from the Orin Nano, rated at up to 40 TOPS of AI performance, to the Jetson AGX Orin at 275 TOPS. This range lets developers scale the same software across small and large robots.
How Embedded Platforms Power Different Robots
Autonomous mobile robots (AMRs). An AMR navigates a warehouse or factory on its own. Its platform fuses lidar and camera data, runs localisation and path planning, and controls the drive motors, all on battery power. Performance per watt matters as much as raw speed.
Collaborative robots (cobots). Cobots work alongside people, so the platform must respond quickly to contact and speed changes. Predictable timing in the motion control loop is more important than peak AI performance.
Industrial robot arms and cells. In a robot cell, an embedded PC often acts as the cell computer. It coordinates the robot, vision system, conveyors and safety devices, and connects the cell to the factory network.
Inspection and vision robots. These robots carry cameras to check parts, welds or infrastructure. AI inference on the platform allows defects to be detected in real time rather than reviewed later.
What to Consider When Choosing
-
Compute balance: decide how much work goes to the CPU and how much to a GPU or AI accelerator. Vision heavy robots need acceleration; simple transport robots may not.
-
Real time behaviour: motion control needs predictable timing. Check real time operating system and fieldbus support.
-
Power budget: on battery powered robots, every watt shortens runtime and adds heat.
-
Interfaces: count the cameras, Ethernet ports, CAN, serial and USB connections you need now and in the next product version.
-
Environment: vibration, shock and temperature ranges differ widely between a clean electronics plant and an outdoor robot.
-
Software ecosystem: confirm support for ROS 2, your AI frameworks and your operating system.
-
Lifecycle: robots are often built and serviced for many years, so long term availability of the platform matters.
Pro tip: Prototype on a development kit, but choose the production platform early. Moving from a hobby board to an industrial platform late in a project often means rewriting drivers and repeating validation.
Common Mistakes
-
Choosing for peak performance only. A powerful processor that throttles in a sealed, hot chassis delivers less than a smaller one that runs cool.
-
Mixing real time control and heavy AI without a plan. Separate them by design, through cores, virtualisation or dedicated hardware, so AI workloads never delay motor commands.
-
Forgetting the next product generation. A COM based design lets you upgrade the processor module without redesigning the entire carrier board.
-
Ignoring certification. Safety functions may need certified components. Plan this from the start.
Expert insight: [PLACEHOLDER: Add a short, genuine comment from an Aaronn Electronic GmbH application engineer, with name and role, about a real robotics project. Do not publish without real input.]
How Aaronn Electronic Helps
Aaronn Electronic GmbH is a manufacturer independent system integrator based in Puchheim near Munich. Whether you are looking for an embedded plattform robotik solution for an AMR, a cobot controller or an edge AI vision system, our team helps you compare SBCs, Computer on Modules and embedded PCs from leading manufacturers and plan for long term availability.
Explore our edge AI solutions or request a free consultation.
Frequently Asked Questions
What is an embedded platform in robotics?
It is the dedicated computing hardware inside a robot that runs perception, decision making, motion control and communication software.
Which embedded platform is best for an AMR?
Most AMRs need a balance of AI acceleration for perception and low power consumption for battery runtime. Edge AI modules and compact embedded PCs are common choices.
Do robots need a GPU?
Only if they rely on vision based AI, such as object detection or grasp planning. Simple transport or pick and place robots can often run on a CPU alone.
What is the role of ROS 2 in embedded robotics?
ROS 2 is open source middleware that connects robot software components. Your embedded platform must support it, along with the drivers and acceleration your application needs.
Conclusion
The embedded platform is the brain of every robot. It handles perception, decisions, motion and communication, and its limits become the robot's limits. Start from your robot's tasks, power budget and environment, then choose the platform type that fits.