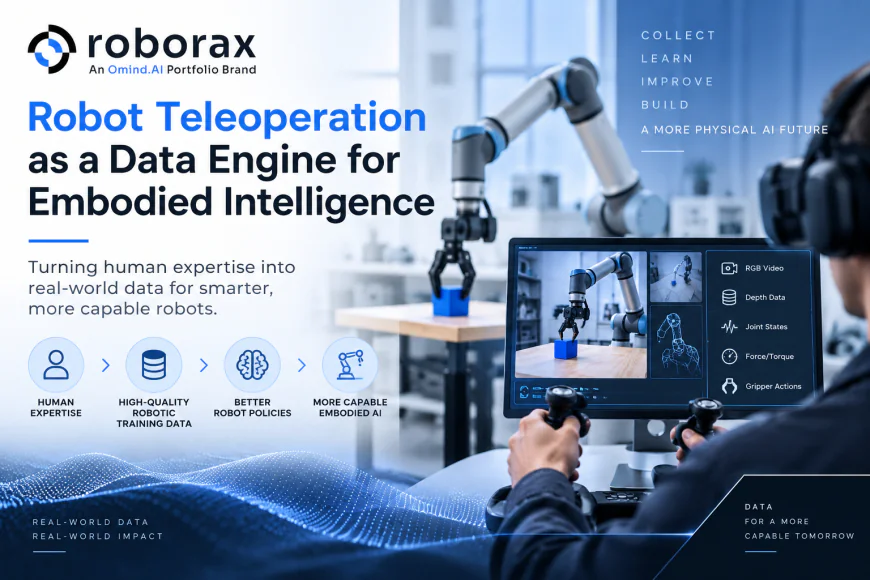
Robot Teleoperation as a Data Engine for Embodied Intelligence
Robot teleoperation transforms human expertise into high-quality robotic training data, enabling robots to learn real-world tasks, adapt to complex environments, and advance embodied intelligence through scalable physical demonstrations.
 roborax
Embodied intelligence requires AI systems to do more than recognize objects or generate text. Robots must perceive their surroundings, understand task context, make decisions, and translate those decisions into physical actions. Achieving this level of intelligence depends heavily on high-quality real-world data that connects perception with action.
This is where robot teleoperation is becoming an important data engine for modern robotics. By allowing human operators to control robots while capturing synchronized actions, sensor readings, and visual observations, teleoperation creates demonstrations that can be used to train and improve robotic policies. Research and industry discussions increasingly identify this action-linked data as an important complement to simulation and human video.
For robotics teams developing manipulation systems, humanoids, mobile robots, and other embodied AI platforms, structured robot teleoperation data collection can provide a practical pathway from human expertise to machine-learnable behavior.
What Makes Teleoperation Valuable for Robot Learning?
Traditional datasets often describe what an object looks like or what a person is doing. Robot learning requires another layer: the relationship between an observation and the action taken in response.
During teleoperation, an operator controls a physical robot through interfaces such as VR systems, leader-follower mechanisms, joysticks, exoskeletons, or specialized control rigs. At the same time, the collection pipeline can record robot states, camera streams, end-effector movements, force information, and other sensor signals.
This creates a state-action trajectory rather than simply a video recording.
For example, a demonstration of a robot picking up a cup can capture:
-
The visual position and orientation of the cup
-
Robot joint positions and velocities
-
Gripper movements
-
End-effector trajectory
-
Force or torque information
-
The sequence of actions leading to successful grasping
-
The final task outcome
Together, these signals form valuable robotic training data for imitation learning, behavior cloning, policy learning, and other approaches to robot intelligence.
Turning Human Expertise Into Machine-Readable Experience
Humans naturally adjust their movements when objects shift, surfaces behave differently, or an action does not work as expected. A robot policy needs examples of these decisions to learn robust behavior.
Teleoperation effectively places a human expert inside the robot's control loop. Instead of attempting to manually program every movement, teams can collect demonstrations of how a task should be performed.
Consider a simple drawer-opening task. A successful trajectory may involve approaching the handle, adjusting the end effector, applying an appropriate force, pulling the drawer, and compensating for resistance. These actions occur within a continuous physical context.
Recording the complete trajectory gives a learning system information about both what happened and how the robot responded.
That distinction is important because embodied intelligence is ultimately concerned with closed-loop interaction between perception and action.
Teleoperation as a Production Data Pipeline
Effective teleoperation is more than putting an operator in front of a robot. The surrounding data infrastructure determines whether demonstrations become useful training assets.
A production-oriented pipeline typically includes four major stages.
1. Hardware and Interface Setup
The robot, cameras, controllers, haptic devices, or leader-follower systems must be configured and calibrated. The objective is to create a reliable connection between operator input and robot movement.
2. Demonstration Collection
Operators perform predefined tasks under controlled conditions. Depending on the project, teams may collect thousands of trajectories covering different objects, environments, task variations, and failure conditions.
3. Synchronization and Quality Assurance
Sensor streams must be synchronized accurately. Joint states, video, force readings, and task events should share reliable timestamps. Poor synchronization can make otherwise valuable demonstrations difficult to use.
Roborax's teleoperation workflow, for example, is designed around synchronized joint, pose, force, and video streams, with outputs packaged for robotics data pipelines.
4. Filtering and Dataset Preparation
Not every demonstration should automatically enter a training set. Failed episodes, inconsistent operator behavior, calibration errors, corrupted recordings, and ambiguous task outcomes may require filtering or separate classification.
A mature dataset therefore represents not only quantity but also consistency, traceability, and usability.
Why Real-World Data Matters for Embodied Intelligence
Simulation can generate enormous volumes of training experience at relatively low marginal cost. However, simulated environments cannot perfectly reproduce every physical interaction, sensor artifact, object variation, or unexpected event encountered in the real world.
Teleoperation addresses part of this gap by collecting data directly from physical robots.
This is especially valuable for contact-rich activities such as:
-
Object grasping and placement
-
Assembly
-
Tool manipulation
-
Opening doors and drawers
-
Folding and handling deformable objects
-
Bimanual coordination
-
Warehouse picking
-
Mobile manipulation
-
Humanoid interaction with everyday environments
Real-world demonstrations expose models to the physical constraints and variability that matter during deployment. At the same time, simulation and human video can complement teleoperation by expanding environmental and behavioral diversity.
Scaling Robotic Training Data
One of the biggest challenges in embodied AI is moving from a small collection of demonstrations to a dataset large enough to support generalization.
Scaling requires more than simply adding operators. Teams need standardized task instructions, operator training, hardware calibration, quality gates, consistent data schemas, and measurable acceptance criteria.
Roborax approaches teleoperation as an operational data service, supporting VR, exoskeleton, and bilateral leader-follower setups and producing synchronized multimodal trajectories. Its broader platform combines teleoperation with annotation, sensor capture, simulation, evaluation, and long-tail data collection.
This model allows robotics teams to treat data generation as an ongoing production pipeline rather than an occasional research activity.
Capturing Failure Is Just as Important
A robot that only sees perfect demonstrations may struggle when conditions change.
For this reason, teleoperation programs can deliberately include edge cases and recovery behavior. An operator might encounter a misplaced object, unsuccessful grasp, unexpected resistance, occlusion, or partial task failure. Recording how the operator responds can provide useful examples of corrective behavior.
These episodes can become particularly valuable for developing policies designed to recover from errors instead of simply repeating a predetermined trajectory.
The result is a richer training corpus containing successful execution, variation, intervention, and recovery.
From Demonstrations to Embodied Intelligence
The ultimate value of teleoperation is not the recording itself. It is the transformation of human physical expertise into structured learning signals.
A well-designed teleoperation dataset can support a progression:
Human control → synchronized demonstrations → quality-controlled trajectories → robotic training data → policy training → evaluation → targeted data collection → improved robot behavior
This creates a feedback loop. Once evaluation identifies where a policy fails, teams can design new teleoperation tasks specifically around those weaknesses. Data collection then becomes targeted rather than indiscriminate.
For embodied AI teams, this can turn teleoperation into a continuous improvement mechanism.
Conclusion
Robot teleoperation is evolving from a method for remotely controlling machines into an important infrastructure layer for embodied intelligence. By connecting human decision-making with physical robot actions, it produces demonstrations that preserve the relationship between perception, movement, and task outcomes.
High-quality robot teleoperation data collection can therefore become a foundation for generating scalable robotic training data, particularly for manipulation, humanoid robotics, mobile robotics, and other systems operating in dynamic physical environments.
The future of embodied intelligence will likely depend on combining multiple data sources rather than relying on one alone. Simulation can provide scale, human video can provide behavioral diversity, and teleoperation can provide robot-grounded action data. Together, these sources can help robotics teams build systems that learn not merely to recognize the physical world, but to act within it.