Intel RealSense™ Depth Camera D455: Features, Specifications, and Applications
Discover the RealSense D455 depth camera, featuring stereo depth sensing, global shutter sensors, an integrated IMU, and applications in robotics, automation, and computer vision.
 SEO.TannaTechBiz
As robotics, automation, and artificial intelligence continue to evolve, machines increasingly need to understand their surroundings in three dimensions. From autonomous mobile robots to industrial inspection systems, accurate depth perception enables intelligent devices to identify objects, estimate distances, and navigate complex environments.
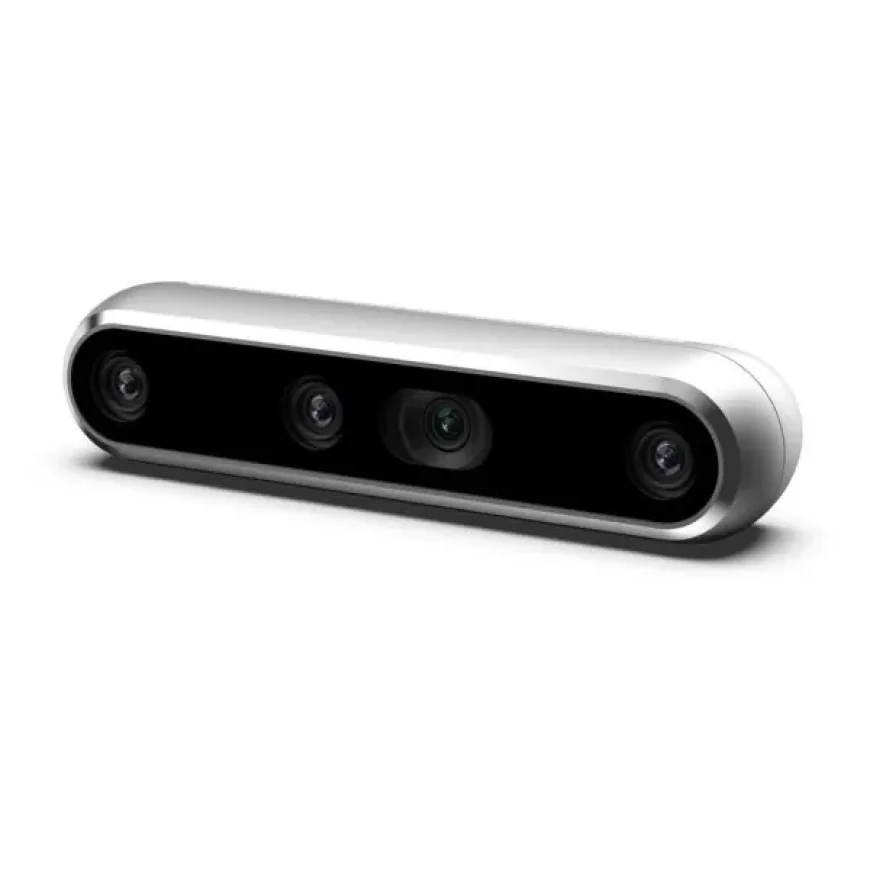
The RealSense™ Depth Camera D455 is designed to support these requirements with stereo depth sensing, high-resolution imaging, global shutter sensors, and an integrated inertial measurement unit (IMU). Its extended stereo baseline helps improve depth accuracy at longer distances, making it a practical option for robotics, computer vision, and other depth-sensing applications.
With support for depth streaming at up to 1280 × 720 resolution and frame rates of up to 90 frames per second (FPS), the D455 provides developers with a flexible vision solution for building intelligent machines and embedded AI systems.
What Makes the RealSense D455 Depth Camera Different?
The RealSense D455 is a stereo depth camera that uses two infrared imagers to estimate the distance between the camera and objects in its field of view. By comparing corresponding features in the images captured by the two sensors, it generates depth information that can be used for 3D perception.
One of its defining features is a 95 mm baseline between the depth sensors. This wider separation helps improve depth accuracy at longer working distances compared with cameras that use a shorter baseline. According to the manufacturer's specifications, the D455 can achieve depth error below 2% at a distance of 4 metres under suitable conditions.
The camera also integrates an RGB sensor and an IMU, allowing developers to combine depth maps, color images, and motion measurements in supported applications.
These capabilities make the D455 useful for systems that require both environmental awareness and reliable spatial information.
Key Features of the RealSense D455
1. High-Resolution Stereo Depth Sensing
The D455 supports depth output at resolutions of up to 1280 × 720 pixels, with frame rates reaching 90 FPS at supported configurations.
High-resolution depth data helps applications estimate object distances, identify obstacles, reconstruct scenes, and understand the geometry of surrounding environments.
This capability is particularly valuable for autonomous robots, 3D scanning workflows, object measurement, and machine vision systems.
2. Global Shutter Sensors for Motion Capture
Motion can introduce distortion into images captured by cameras with rolling shutters, particularly when objects or the camera move quickly.
The D455 uses global shutter technology for its depth imagers and RGB sensor. Global shutters capture each frame across the sensor at the same time, helping reduce motion-related distortion during image acquisition.
This makes the camera suitable for dynamic environments, including mobile robotics, moving platforms, and automated inspection systems.
3. Extended Depth Range and Improved Accuracy
The D455 is designed for applications that require depth perception beyond close-range object detection.
Its recommended operating range is approximately 0.6 to 6 metres, while actual usable range depends on lighting, scene texture, surface reflectivity, and other environmental conditions.
The extended baseline helps improve depth measurement performance at longer distances. This can be useful when a robot needs to detect obstacles ahead, estimate the position of objects across a workspace, or map a larger operating area.
4. Integrated IMU for Motion Awareness
The camera includes an inertial measurement unit based on the Bosch BMI055. This sensor provides motion-related measurements that applications can use alongside depth and image data.
Combining IMU measurements with visual information can support tasks such as motion estimation, sensor fusion, and robotic localization.
For example, a mobile robot can use camera data to perceive its surroundings while incorporating inertial measurements into a broader navigation system. The final performance depends on the algorithms, calibration, and other sensors used in the system.
5. RGB Imaging and Depth Data
In addition to depth sensing, the D455 provides a color image stream at up to 1280 × 800 resolution and 30 FPS.
Combining color and depth data allows applications to associate spatial measurements with visual features. This can improve object recognition, scene understanding, and the interpretation of 3D environments.
Potential uses include identifying objects by color and shape, locating objects in three-dimensional space, and developing augmented visualization systems.
RealSense D455 Technical Specifications
The RealSense D455 Depth Camera features stereo vision technology with a depth resolution of up to 1280 × 720 pixels and a maximum depth frame rate of 90 FPS. It supports RGB imaging at up to 1280 × 800 pixels and 30 FPS, with an approximate depth field of view of 87° × 58°. Designed for depth sensing at distances of approximately 0.6 to 6 metres, the camera can achieve less than 2% depth error at 4 metres under specified conditions. Its 95 mm stereo baseline and global shutter sensors help improve depth measurement and image capture in dynamic environments. The camera also includes an integrated Bosch BMI055 inertial measurement unit (IMU) for motion sensing. With a USB-C interface supporting USB 3.1 Gen 1 and compact dimensions of approximately 124 × 29 × 26 mm, the RealSense D455 is suitable for robotics, computer vision, 3D mapping, and industrial automation applications.
Specifications and achievable frame rates can vary with stream configuration, host bandwidth, firmware, and operating conditions. Refer to the manufacturer's documentation for the exact supported modes.
Applications of the RealSense D455 Depth Camera
The combination of depth sensing, color imaging, and motion data makes the D455 suitable for a broad range of intelligent vision applications.
1. Robotics and Autonomous Navigation
Robots need to identify obstacles, estimate distances, and understand their surroundings to move safely and efficiently.
The D455 can provide depth information for obstacle detection, environment mapping, object localization, and navigation systems. When combined with suitable software and additional sensors, it can support robotic perception pipelines for autonomous mobile robots, service robots, and research platforms.
It is also useful for developers working on simultaneous localization and mapping (SLAM), where visual and spatial information helps a robot estimate its position while building a map of its environment.
2. Industrial Automation and Machine Vision
Industrial systems increasingly rely on three-dimensional information to automate tasks that would be difficult to perform with conventional cameras alone.
The D455 can support applications such as object positioning, dimensional estimation, robotic pick-and-place operations, and workspace monitoring.
For example, a robotic arm can use depth data to estimate the position of an object before attempting to grasp it. In inspection environments, 3D information can help identify variations in object placement or surface geometry.
Actual suitability for production environments depends on required accuracy, ambient lighting, operating distance, and industrial integration requirements.
3. AI and Computer Vision
AI models often require more than a conventional two-dimensional image to understand the spatial relationships between objects.
The D455 supplies depth information that can complement image-based AI models. Developers can combine its data streams with computer vision algorithms for object detection, segmentation, tracking, and 3D scene analysis.
When paired with an edge computing platform such as an NVIDIA Jetson system, it can form part of an embedded AI solution that processes visual information locally.
This combination is useful for applications that require real-time perception without depending on continuous cloud connectivity.
4. 3D Mapping and Environment Reconstruction
Depth cameras are widely used in applications that need to estimate the shape and layout of a physical environment.
The D455 can provide depth frames for 3D mapping, point-cloud generation, spatial analysis, and environment reconstruction. With suitable software, multiple depth frames can be combined to build a representation of a room, workspace, or operating area.
Potential applications include robotics research, facility mapping, interactive environments, and spatial measurement prototypes.
The quality of the resulting 3D model depends on camera movement, calibration, scene characteristics, and the reconstruction algorithms used.
5. Drones and Mobile Platforms
Mobile platforms need to perceive obstacles and estimate distances while moving through changing environments.
The D455's global shutter sensors and integrated IMU make it relevant to certain mobile robotics and autonomous platform projects. It can supply depth and visual information for obstacle awareness, object tracking, and navigation research.
However, developers must account for camera weight, power consumption, mounting stability, vibration, operating conditions, and host-system compatibility when integrating it into a drone or other mobile platform.
6. Research, Education, and Prototyping
The D455 can also support research and educational projects involving computer vision, robotics, and 3D perception.
Students, researchers, and developers can use depth data to experiment with object detection, visual odometry, point clouds, scene reconstruction, and sensor fusion.
Its USB connectivity and supporting software tools help simplify integration into compatible development systems, making it a useful component for prototyping new vision-based applications.
Integrating the RealSense D455 with NVIDIA Jetson
For developers building edge AI applications, combining a RealSense D455 with an NVIDIA Jetson platform can provide a compact vision and computing solution.
The camera captures depth and color information, while the Jetson platform can process those data streams using compatible computer vision libraries and AI frameworks.
A typical integration workflow includes:
- Connect the camera: Use a compatible USB 3 connection and verify that the carrier board and host system provide sufficient bandwidth and power.
- Install the software: Set up a compatible version of the RealSense SDK and the required system dependencies.
- Verify camera streams: Test depth, RGB, and IMU data where required, and confirm the selected resolutions and frame rates.
- Develop the perception pipeline: Process depth frames, generate point clouds, or combine camera data with compatible AI models.
- Optimize deployment: Measure processing latency, USB bandwidth, memory usage, and overall system performance under the intended workload.
Compatibility should be checked before selecting hardware. The Jetson module, carrier board, operating system, kernel, SDK version, and application libraries must work together.
Why Choose the RealSense D455 for Your Project?
The D455 offers several advantages for developers building systems that need reliable spatial awareness:
- Stereo depth sensing: Provides distance information for 3D perception and spatial analysis.
- Extended stereo baseline: Helps improve depth accuracy at longer working distances.
- Global shutter imaging: Reduces motion-related image distortion.
- Integrated IMU: Supplies motion measurements for supported sensor-fusion applications.
- RGB and depth streams: Combines visual appearance with spatial information.
- Flexible integration: Supports compatible USB-connected development systems and embedded computing platforms.
Before selecting the camera, evaluate your working distance, lighting conditions, required depth accuracy, frame rate, field of view, and host-system compatibility. These factors help determine whether the D455 is the right choice or whether another depth camera would better suit the application.
Sourcing the RealSense D455 Depth Camera in India
For businesses, research institutions, startups, and system integrators in India, sourcing suitable depth-sensing hardware is an important part of developing robotics and AI solutions.
Tanna TechBiz LLP, based in Rajkot, Gujarat, supplies technology components for embedded computing, robotics, IoT, and AI applications. Teams evaluating the RealSense D455 can consult their supplier to confirm current availability, product configuration, accessories, and compatibility with their intended platform.
Before purchasing, verify the camera's availability, included accessories, USB requirements, software compatibility, and suitability for the planned application. For production projects, it is also advisable to validate the camera under the actual operating conditions.
Conclusion
The RealSense D455 Depth Camera is a capable stereo vision solution for applications that require depth perception, color imaging, and motion-related data. Its 95 mm stereo baseline, global shutter sensors, integrated IMU, and support for high-frame-rate depth streaming make it a useful option for robotics, machine vision, 3D mapping, and embedded AI development.
When integrated with compatible computing hardware and software, the D455 can help developers build systems that interpret their surroundings with greater spatial awareness.
For engineers and businesses developing intelligent machines, the RealSense D455 offers a flexible starting point for turning visual data into actionable spatial information.